

Sharpa is an AI robotics company dedicated to developing ultra-high performance robots and core components. We Manufacture Time by Making Robots Useful.
United States
- Tweets 331
- Following 199
- Followers 5,774
- Likes 1,161

Sharpa will be co-hosting two competitions at IROS 2026.
Powered by Sharpa's robot platforms and software, the 2nd ROCO and Origami challenges (cohosted by @BitRobotNetwork) brought together 48 teams from leading institutions around the world—including Carnegie Mellon University, UC Berkeley, KAIST and NUS.
Across both competitions, teams will put robotic manipulation and dexterity to the test on Sharpa hardware through challenging real-world tasks.
Follow the challenges for more:
ROCO: @NtuLab38456
Origami: robotic-origami-challenge.gi…

5
8
56
13,147
Excited to announce: three new Sharpa products are making their debut at IROS — all developed in-house!🚀
Meet the lineup:
D01 — general-purpose humanoid robot
W02 — next-generation dexterous hand
AE01 — exoskeleton data glove
Discover what’s next in dexterous manipulation. See you in Pittsburgh!
📅 September 27–30
📍 Booth 514 · David L. Lawrence Convention Center
Pittsburgh, PA, USA
#IROS #Sharpa #Robotics #HumanoidRobotics #DexterousManipulation #DexterousHand #EmbodiedAI #RobotLearning #Teleoperation


4
8
128
7,579
We've been privileged to help some of the best teams advance general-purpose robotics models.
Teams at @NVIDIARobotics working on #GR00T and EgoScale. Teams at @GoogleDeepMind shaping the new Gemini Robotics 2 model family. Researchers at @Stanford evolving RL policy training for dexterous manipulation. Researchers at @UCBerkeley pushing tactile policy learning forward. And many others we're proud to support quietly.
That work has been a constant source of validation, on the need for dexterous hardware, and on the robustness and quality bar it has to meet. It's a sign the field is getting closer to real scaling laws, and closer to an inflection point in robotics autonomy.
This is exactly why we've spent the past stretch strengthening our manufacturing and scaling production. More capacity. Faster lead times. More Wave units getting into the hands of the teams pushing the field forward.
Reach out to know more (link in comments).
#Robotics #EmbodiedAI #DexterousManipulation #RoboticsHand
5
3
32
2,033
Episode 4/4 — Same Kitchen. Same Equipment. Same Recipe. Real Customers.
Building a general-purpose robot means it fits into a human environment, doing what a person does, not the other way around.
At DQ: same kitchen, same equipment, same recipe. As @GoingBallistic5 put it, "absolutely no modifications whatsoever." No special dispenser, no custom handles, no rewritten process.
That puts all the pressure on the robot. Retrofitting is the easy way out and the last thing a partner like DQ wants is to change what it's spent decades perfecting.
North starts its first real shift at DQ Shanghai end of August.
#Sharpa #SharpaNorth #EmbodiedAI #PhysicalAI #AIRobotics #DQChina #UsefulRobots @roydendsouza @mehrdad_Frimani

1
2
37
6,566
Did you know it takes #DQChina staff a full week of training to master blending a Blizzard? It's more complicated than it looks.
Now imagine North having to learn the same move. A thin paper cup faces constantly shifting torque from thick, uneven ice cream. As @GoingBallistic5 put it, too little grip and it slips. Too much, and it crushes.
It's hard for a parallel-jaw gripper to solve this: it only pinches from two sides.
Wave doesn't pinch, but wraps. A five-finger grasp spreads the load and adjusts grip in real time as torque shifts, letting North run this exact motion autonomously.
#SharpaWave #SharpaNorth #DexterousHands #EmbodiedAI #PhysicalAI #AIRobotics #DQChina #Blizzard #overthehorizon @roydendsouza @Hmorvaridi

5
13
110
28,258
Episode 2 — Full Stack, Not Just a Hand
Sharpa is often known for Wave, our dexterous hand. But a hand can't run a shift on its own.
@GoingBallistic5 nailed it: North's DQ deployment shows "not just their hands, but the entire stack" — including our own embodied AI.
Underneath: a world model predicting physics, CraftNet controlling motion, and within CraftNet our System 0, adjusting grip in real time through touch.
No retrofits nor custom equipment. Our embodied AI adapts to the real world, not the other way around.
Next: we put the stack to the test.
#Sharpa #SharpaNorth #SharpaWave #EmbodiedAI #PhysicalAI #AIRobotics @roydendsouza @Hmorvaridi

8
18
86
8,254
Full video from Over The Horizon: piped.video/watch?v=QuEtIZdM…
1
8
797
Episode 1 — We manufacture time by making robots useful
This August, North steps behind the counter at a real DQ store in Shanghai; and it will be a full shift, with real customers, real orders, and of course, real ice cream.
@GoingBallistic5 nailed it: North isn't a replacement for workers, it's a "substitute," filling in or augmenting the workforce where it's needed.
The North robot adds capacity when teams are understaffed, late shifts are hard to fill, or repetitive work keeps people from more valuable tasks.
@Hmorvaridi caught exactly what we meant with the football scene: people enjoy the match while North takes the shift.
@roydendsouza linked it back to our mission: We manufacture time by making robots useful. Thanks, Royden, for pointing out that it is "the best worded mission" you've seen in a long time.
Stay tune for the next episode!
#Sharpa #SharpaNorth #UsefulRobots #EmbodiedAI #AIRobotics #overthehorizon

4
21
138
18,102
#SharpaWave helped train & test @GoogleDeepMind's Gemini Robotics 2.
Backward compatible: the Wave adapts to any environment, object, or task. Same trash bags: no redesigned trash can. Same ziplock bags: no bulky boxes swapped in to make gripping easier. The hand fits the world, not the other way around.
Fidelity matters too: Wave is designed to be anthropomorphic, with tactile resolution that captures the high quality data that human demonstration actually contains.
#EmbodiedAI #PhysicalAI #Robotics #DexterousHands

5
3
33
6,375
The task of the #IROS2026OrigamiChallenge is to fold a traditional paper airplane in 6 folds. It's one of the hardest manipulation benchmarks around: paper is thin, deformable, easy to occlude, and unforgiving of contact timing.
A successful policy has to coordinate two arms, two dexterous hands, tactile feedback, and multi-view vision over a long sequential horizon.
1
1
56
22,499
We're releasing the Origami Dataset we prepared for the #RoboticOrigamiChallenge we co-organize with @chris_j_paxton @micoolcho, @DJiafei and @lightwheel for #IROS2026!
It's one of the largest tactile datasets out there and it's built on #SharpaWave, our 22-DoF five-finger tactile hand. It shows both head & wrist camera views; and records deformation and tactile patterns from the fingertips as the paper folding task unfolds.
What's in the dataset:
1. 682 episodes across 51 collection seasons, 4.76M frames at 30 FPS
2. 6 synchronized camera views plus
3. 10 fingertips x 6-axis force/torque signals, synchronized frame by frame with vision and motion
4. 2 tactile video formats: a raw sensor stream for maximum fidelity, and a lighter deformation map
5. 65D joint-space state and action across two arms and two dexterous hands
6. Full LeRobot 3.0 coverage across all seasons, ready to drop into existing pipelines for long-horizon imitation learning, and/or visual-tactile representation learning
Dataset on Hugging Face: huggingface.co/datasets/Shar…
Wave URDF & tactile assets: sharpa.com/pages/open-source
#RoboticOrigamiChallenge #HuggingFace #Robotics #TactileSensing #EmbodiedAI #IROS2026 #TactilePolicies #Robots #PhysicalAI #datasets
3
30
165
21,365
Most robot teleoperation copies hand motion but not "feel" so the robot crushes or drops whatever it's holding, and you throw the demo away.
A new @NTUsg paper (from Research Fellow Haichao Liu, Dr. Ziwei Wang & team) addresses this: the robot reads its own fingertip tactile feedback and auto-corrects grip force in real time, while the human stays in control of the motion.
Result: success on a hard assembly task went from 4% → 97%, using less than half the force.
The bottleneck in dexterous robots training is also about collecting clean data where nothing got crushed along the way. This research help closing the gap. So do the #SharpaWave, that enable high quality data collection for complex manipulation tasks, like screwing.
Link to the paper in comments!
#DexterousManipulation #TactileSensing #AIRobotics #NTU #Dexteroushands #Robots #Teleoperation

4
9
39
7,875
Your first robot-handmade ice cream🤖🍦.
Delivered to you by #SharpaNorth & DQ China this August in Shanghai.
Autonomous. End-to-end. Full shift.
Real store. Real customers. Real orders.
#Sharpa #SharpaNorth #Shanghai #SharpaWave #AIRobotics #EmbodiedAI #PhysicalAI #robots #UsefulRobots #WorldModel #Blizzard #Oreocrumbs #icecream #worldcup

9
17
130
764,521
Sharpa at #RSS2026 in Sydney! Two North robots and our Wave hands sparked great conversations with the community working on manipulation and deployment bottlenecks.
— Dr. Yunfang Yang on the Sharpa platform: hands, humanoid, AI models
— Kaifeng Zhang, our Head of Academia, on our latest research
— Met some of the best AI research talent in the field
Building embodied AI? Come talk to us.
#RSS2026 #AIRobotics #DexterousManipulation #SharpaWave #EmbodiedAI #SharpaNorth #VLA #PhysicalAI

4
5
30
2,138
🚀 We're coming to RSS 2026 in Sydney!
Come to our booth near the main entrance to see how our dexterity-first technologies enable robust real-world productivity.
We're looking forward to meeting researchers, engineers and founders from across the AI robotics community.
📍 Main Entrance
📅 July 13–16
📍 ICC – Sydney
Stop by and say hello—we'd love to connect.
#Sharpa #RSS2026 #Robotics
#EmbodiedAI
#DexterousManipulation
#TactileSensing
#HumanoidRobotics

1
19
1,375
NVIDIA's new CHORD framework teaches robot hands to manipulate objects by matching how human contact moves an object. Learned from human demos and transferred to real dexterous hands.
Look at the high success rates: 82.12% success across 1,831 contact-rich tasks; 90.77% success on whole-body manipulation. With policies deployed from simulation.
That's the #SharpaWave in the loop :)
Project: nvidia-isaac.github.io/video…
Paper: nvidia-isaac.github.io/video…
#PhysicalAI #DexterousManipulation #RobotLearning #NVIDIA #EmbodiedAI #Robotics #Dexteroushands

1
19
130
8,231
Before a robot can perfect assembly, it needs to learn to play.
The team behind SimToolReal @kushalk_ @tylerlum23 @leto__jean @KarenJLiu published another cool paper! Play2Perfect pretrains on diverse, task-agnostic play (grasp, reorient, reach, etc), then finetunes on sparse-reward assembly.
Result: 33× sample efficiency vs. training from scratch, and zero-shot sim-to-real down to 0.5mm clearance.
Peg insertion, screwing, multi-part assembly: all running at 60Hz, real speed, real hardware. And when a grasp slips, the policy doesn't stop, it recovers and keeps going.
The Sharpa Wave responded present again ;)
Project: play2perfect.github.io
#Robotics #SharpaWave #Sharpa #EmbodiedAI #DexterousManipulation #RobotLearning

4
24
162
13,932
What if the next leap in robot manipulation comes from touch, not just vision?
To get there, foundation models need to understand tactile feedback the way they understand images and language. And tactile policies cannot be locked to specific hardware (that makes real-world deployments & maintenance quite complicated).
FTP-1 solves both. One of the 1st foundation model for touch. 21 sensors. ~3,000 hours of data. Transfers to hardware it has never seen before.
+17% on known hardware. +31% on never-seen hardware.
We're proud this research led by @michaelyuancb ran on #SharpaNorth, #SharpaWave hands, and our DTC sensors.
Special thanks to the teams at @Tsinghua_Uni , @UCBerkeley , @ETH , and @sjtu1896.
Project page: ftp1-policy.github.io/

5
25
112
8,129
North recently tried ironing. This week: shirt folding. 👕
Unlike ironing, folding is a skill even the most reluctant of our engineers have mastered.
Notice how smooth the hand movements are. Clothes deserve some respect. 😉

14
29
196
15,474
The dataset was collected using two Sharpa Wave hands, using our high-resolution Dynamic Tactile Arrays on each fingertip to capture the dynamic touch signals needed for contact-rich manipulation.
T-Rex proves that anthropomorphic hardware and tactile-reactive software are co-dependent :) Amazing work @Dantong_Niu !
P.S. The Wave's Isaac Sim URDF/USD assets and tactile parameters are available here if you wanna take a closer look: sharpa.com/pages/downloads

1
4
818
Robots need to feel the world to operate in it.
Most manipulation policies today are tactile-blind. They either cannot interpret high-frequency tactile signals or treat them as a static channel. And the field lacks enough touch-rich datasets to train tactile-reactive policies at scale.
T-Rex was built to answer both. @Dantong_Niu and team, advised by @DrJimFan, @drfeifei, @JitendraMalikCV, @pabbeel @trevordarrell have tested whether a robot policy can react to high-frequency tactile signals the way human hands do, without giving up the generalization power of modern VLAs.
The result: 65% average success rate across 12 real-world tasks. +30 absolute points over the strongest baseline. In one year, tactile VLAs have gone from promising to outperforming non-tactile baselines like pi0.5 on dexterous tasks.
#Robotics #SharpaWave #Sharpa #EmbodiedAI #DexterousManipulation #TactileSensing #RobotLearning
Project link: tactile-rex.github.io/

9
21
132
12,972
We can use videos from the internet to teach robots!
Do as I Do, from
@bhawna_paliwal_ , @HarithejaE , and Willian Liang at UC Berkeley — advised by @pabbeel, @notmahi, and @JitendraMalikCV, used an algorithm that reconstructs hand-object interactions from monocular RGB video and retargets them into real, executable trajectories for multi-fingered dexterous hands. Just using "low quality" video footage of humans doing tasks. No sensors.
The Sharpa Wave robot hand being anthropomorphic, it matches human kinematics. Not only that works, but at fast speed, too!
Congrats to the team, that's super exciting!
Project: do-as-i-do.com/
#Robotics #SharpaWave #Sharpa #EmbodiedAI #DexterousManipulation #RobotLearning

3
15
94
11,162
#ICRA2026 highlights:
- @leto__jean and the @NVIDIARobotics team featured the Sharpa Wave in their SimToolReal and EgoScale talks 🙏
- We caught up with researchers and partners from around the world
- North handed out Austrian chocolates 🍫
- There were many kids in the audience. Austria starts teaching robotics early 👀
See you at RSS!
#ICRA2026 #AIRobotics #Robotics #IEEE #DexterousManipulation #TactileAI #Vienna #SharpaNorth #SharpaWave #DexterousHand

5
20
1,949
Question to the community: if a robot could iron your clothes, would you wear shirts?
Asking for our engineers🙃.

15
16
81
12,363
Touch alone isn’t enough. 🖐️
For robotics, tactile intelligence truly levels up when touch gains spatial meaning.
At #ICRA2026, we dove into the core concept behind SaTA: Spatially-anchored Tactile Awareness for robust, dexterous manipulation. Read it here: arxiv.org/html/2510.14647v1.
The challenge is fundamental: a robot shouldn’t just register a touch, it needs to understand exactly where that contact occurs relative to its fingers, joints, and overall hand structure.
This is the missing link that turns raw data into precise, real-time adjustments during manipulation.
Why does this matter? Because the most complex part of any manipulation task happens when vision is at its least reliable, that final millimeter before insertion, sliding, gripping, or fine-tuning.
At Sharpa, this is exactly why we’re building tactile hands and tactile AI in tandem. 🚀
#Sharpa #Robotics #EmbodiedAI #TactileIntelligence #ICRA2026 #DexterousManipulation
📷

6
30
199
15,387
Looking forward to seeing you at #ICRA2026.
Featured events include:
1. June 1st, 15:10 at Stolz 2: Dr Yunfang Yang will be talking about dexterous hands
2. June 2nd, 11:00 at Lehar 1-4: Kaifeng Zhang, Head of Academia, will introduce Spatially-anchored Tactile Awareness research for robotics dexterity
And of course, see you at Booth #33 in Hall B.
Enjoy ICRA, everyone 😄

1
698
We will be at ICRA in Vienna next week.
We first revealed our first product, the Wave dexterous hand, at the same time during ICRA last year. Since then we've delivered the Wave to research labs across the world, built our full body robot North, and developed our tactile AI Craftnet that gives robots a reflex-like intelligence for manipulation tasks.
Come to Booth #33 to see for yourself how we're advancing manipulation skills in robots!

1
12
1,093
Reposting to help the #RoCoChallenge team out 🙌
If you're a scrappy engineer or researcher who wants to take on real assembly tasks with robots — this is for you.
The 2026 RoCo Challenge at #IROS26 in Pittsburgh is expanding to more robot embodiments (bimanual grippers, dexterous hands) and 2 tracks (industrial board assembly + brick assembly)
⚠️ Live info session on May 21 at 9:30 PM EST rocochallenge.github.io/RoCo…
Submissions close Jun 22. Finals Sep 30.
#Robotics #EmbodiedAI #PhysicalAI #Assembly #Dexteroushands #RoCo

1
8
1,462
It’s been a massive week for embodied AI foundation models: the pace of this field is truly staggering.
Throwing it back to the SimToolReal work by @kushalk_ and @tylerlum23 (Cornell & Stanford labs). In February, they achieved zero-shot tool manipulation across 24 tasks using a single RL policy and a robotic arm fitted with the SharpaWave hand.
Watching the robot nail these high-speed in-hand rotations is incredible. The precision is especially impressive when you consider the policy was never trained on these specific objects or tasks. This is what solving the manipulation bottleneck looks like. ⚡️

9
35
291
868,572
Then we compromised the card deck integrity. He still focuses on making the reading right, but let's face it, he wouldn't be a good professional blackjack dealer 😂

2
1
11
1,077
Teasing North robot, part 2: This time, we're messing with the card deck. Regardless, he doesn't deviate from the "mission" :)

5
3
40
5,150
The real world is messy. Adapting to changing conditions will make the difference between a demo and a product. Getting ready!

2
5
732


Teasing North on autonomous pinwheel assembly. High precision, zero ego. It stays focused on the task😎

3
8
25
1,933
Our VP of GTM & President of Europe Alicia Veneziani sat down with NBC to tackle the most important question in robotics: what makes a robot useful?
The key is the hand, the most generalist tool ever built for daily life. What would you want your Sharpa robot to help with?

3
4
22
1,521
Feeling something slip and correcting it in 0.02 seconds. Humans do it without thinking. Robots couldn't. Until now.
Our VP of Research presented CraftNet at GTC 2026, our system that layers tactile AI directly onto Vision-Language-Action models, giving robots a genuine sense of touch and the ability to adapt in real time during contact.
Jensen Huang's keynote recognized our work directly. NVIDIA demonstrated Sharpa Wave within Isaac Lab, GR00T and TacMap to bridge the sim-to-real gap in simulation training.
Touch is the sense we take for granted the most. You've never once thought about how your fingers adjust handing someone a full cup of coffee. Robots have to learn that from scratch.
We gave robots a sense of touch. What comes next?

2
6
21
2,906
Watch how Sharpa's robotic hand handles a tennis ball with and without tactile feedback.
CraftNet System 0, Sharpa's "interaction brain", enables real-time control through tactile and force feedback. It adjusts during contact, allowing robots to handle objects with precision.
Without it, robots can see the object but can’t properly adjust once they touch it, leading to dropped or mishandled objects.
This is how robots become truly useful in the real world.
#Robotics #DexterousHands #technology #humanoid

4
5
62
3,156
Sharpa Robotics is proud to be part of the @nvidia Inception Program.
Our VP of GTM and President of Europe, Alicia Veneziani @AliciaV_0726 met with Howard Wright @hgw1967, Benjamin Chan, Pei Yi Pang, and Andy L. from the NVIDIA Inception team and exchanged ideas on the future of physical AI and robot dexterity.
We’re excited to continue partnering with NVIDIA to advance dexterous, general-purpose robotics in real-world settings.
#NVIDIAinception #sharparobotics #GTC2026 #NVIDIA #physicalAI #dexterousrobotics


4
15
1,446
Proud to host two robotics evangelists in the Sharpa office and see them engage hands-on with our robotic ecosystem.
@IlirAliu_ and @TheHumanoidHub spent time teleoperating our Sharpa Wave 22-DoF dexterous hand and enjoyed playing blackjack with our humanoid robot North experiencing firsthand what coordinated manipulation and real-time control feel like in practice.
Thanks for the visit, the energy, and for continuing to push the robotics ecosystem forward.


2
6
33
11,629
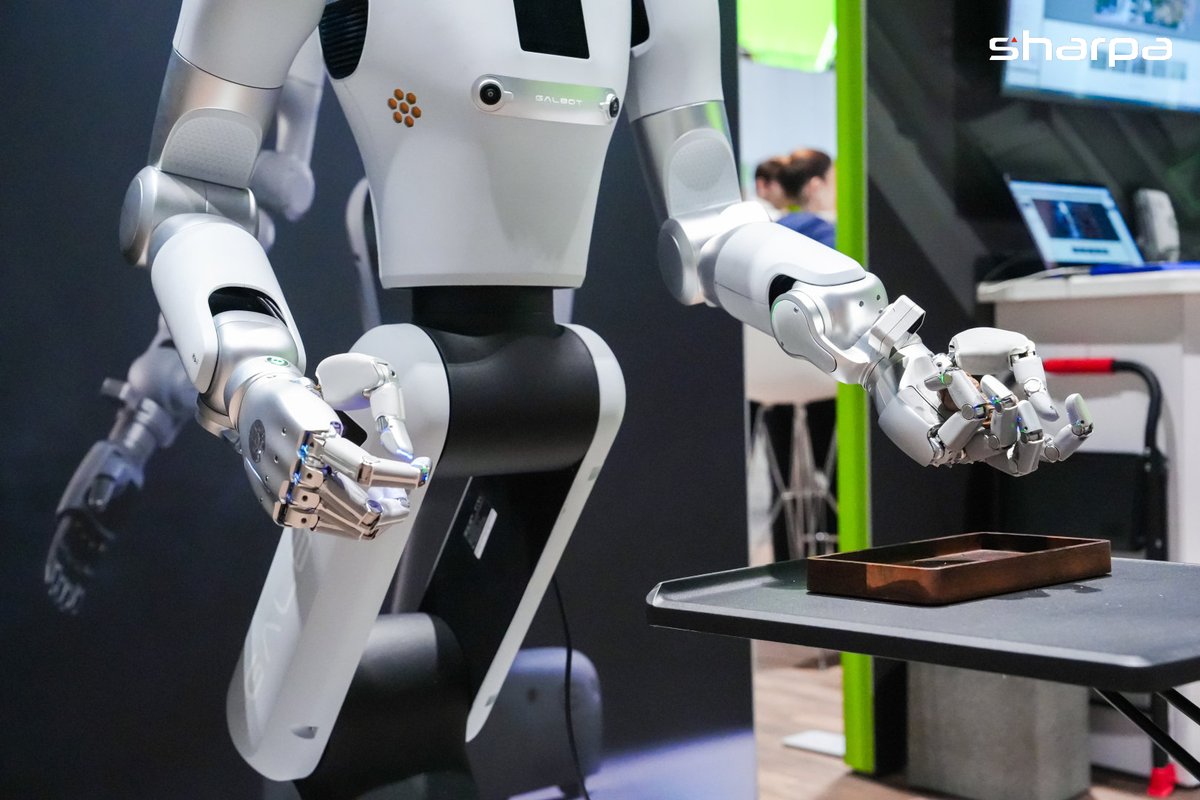
We’re grateful to be shaping the robotics ecosystem with Sharpa Wave, empowering partners with dexterous robotic hands.
@GalbotRobotics is integrating our hands into their robot bodies, while @ManusMeta is using Sharpa Wave with NVIDIA Isaac Sim for teleoperation and simulation - spotlighting our collaboration in their NVIDIA presentation.
We’re excited to continue building partnerships around dexterity and tactile intelligence.



5
10
53
3,723
He couldn't help teasing the Wave and submitting it to the toughest resistance stresses!
We believe that he was impressed by the hand's responsiveness, agility and grip strength!
We really enjoyed the discussions on tactile AI, and real-world deployment. Thanks to Roland Roventa for joining us as well.


11
1,163
We recently had the pleasure of hosting the one and only Scott Walter @GoingBallistic5 at Sharpa.
During his visit, he met with our VP of GTM, Alicia Veneziani @AliciaV_0726 and our technical team, who walked him through our tactile-driven approach to dexterous manipulation.
He controlled the Sharpa Wave using Manus gloves, even playing catch in real time! He also beat our autonomous dealer robot at blackjack, making a perfect 21!


4
14
81
9,033